
Balancerator: gyro-noise quantities
ARW 0.5487, BI 8.62 — first below target, second still above
need the stationary recording + exact Allan-curve fit region. 'gyro noise' is way too vague a label
Terms: angle random walk describes the integrated effect of rate noise; bias instability describes drift in the gyro bias. The notebook records ARW = 0.5487°/√hr and BI = 8.62°/hr, alongside Allan-deviation references. The provenance and fitting interval of those numerical estimates need checking before treating them as a complete calibration record.
Compare with the Day 4 targets: ARW below 1°/√hr and bias instability below 3°/hr. On the numbers written in the notebook, the ARW value is below the target and the BI value is above it; the entry should not be summarized as all noise criteria passing.
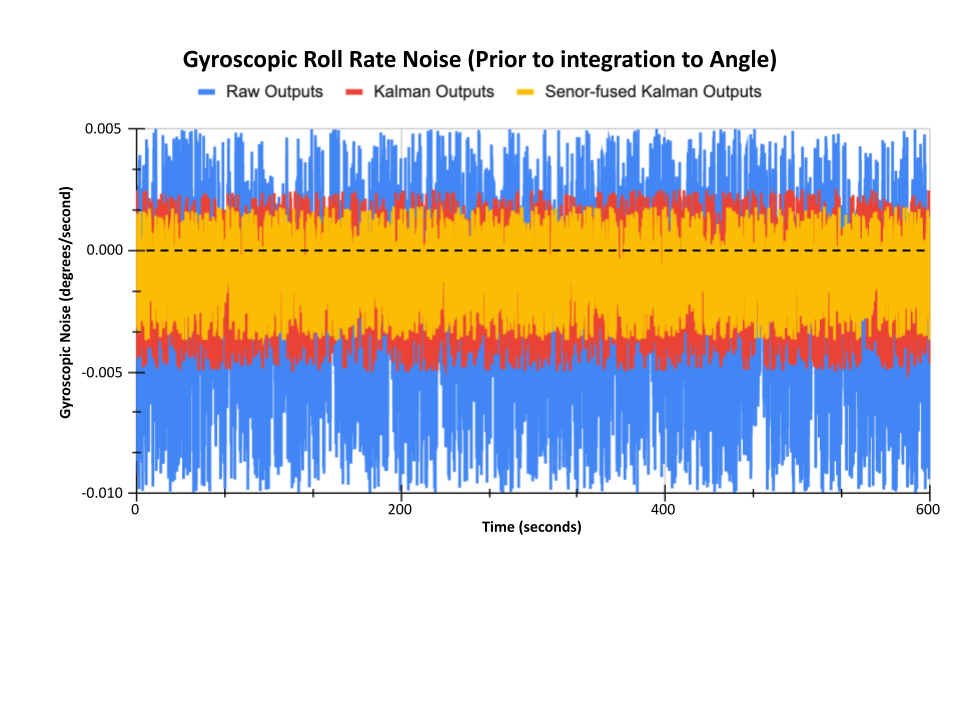
Raw, Kalman-filtered and sensor-fused angular-rate traces.
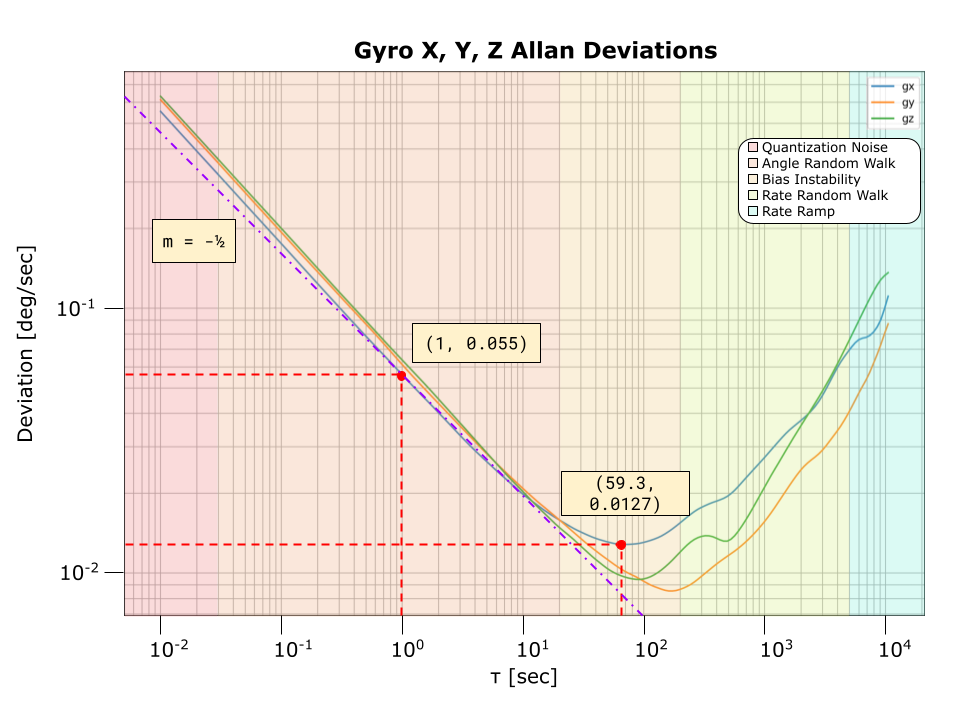
JIC gyro Allan-deviation plot.
Reading: gyro-noise analysis, Allan-variance walkthrough, cited sensor paper.
Review questions: where is the stationary recording, what is its duration, and which portions of the Allan curve produced each estimate?