
Balancerator: MPU6050 connection and example failures
sensor solder joints kept breaking. taped contact was enough to try readings, not enough for wearing this
second level example gave angular rates — save axes / units / offsets / actual loop dt
- hardware problem: solder joints between the sensor and wires repeatedly broke. A taped temporary contact allowed testing, but did not establish a mechanically reliable wearable connection.
- software problem: the first example failed to load its I2C dependency and performed more processing than the project needed. A different electronic-level example produced angular-velocity readings in the serial monitor.
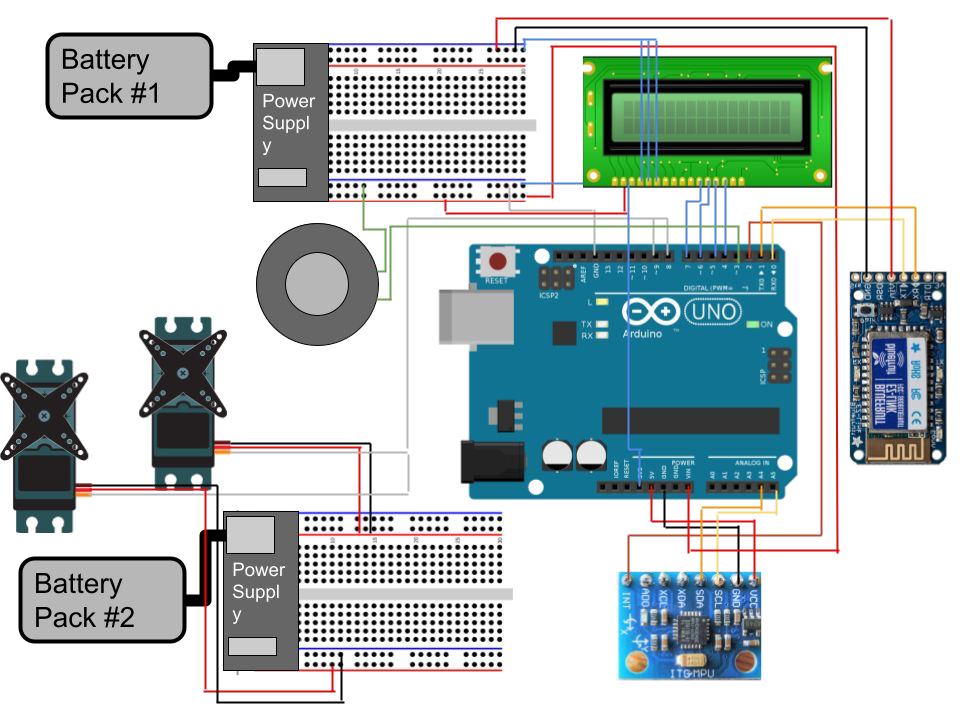
Balancerator wiring and pinout diagram.
- pointers: MPU6050; the source's second electronic-level example; Day 23 for connection observations. Keep sensor bring-up separate from angle estimation and fall-detection logic.
- review questions: log sensor axis orientation, units, stationary offsets and sample interval before using readings in the servo calculation. Successful live readings are not evidence that intermittent contact or drift has been solved.