
THALis: feasibility, information and proportional-control drafts
feasibility / information bounds / proportional control — related but not the same problem. need to get from a continuous estimate to an actual command, smoothing class probabilities isn't the whole thing
documents added (82921aa, c4d44f0): feasibility drafts, Fisher-information bounds, loss/condition drafts, revised proposals and prop_control.tex/pdf. The same period introduces electrode_stencil.py and a cap-stencil PDF.
reference distinctions: feasibility asks whether an intended observation/readout relationship can hold; information bounds concern limits under a specified model; proportional control concerns mapping continuous decoder output to a smooth control signal. A discrete class-probability pipeline does not automatically implement continuous dexterous control.
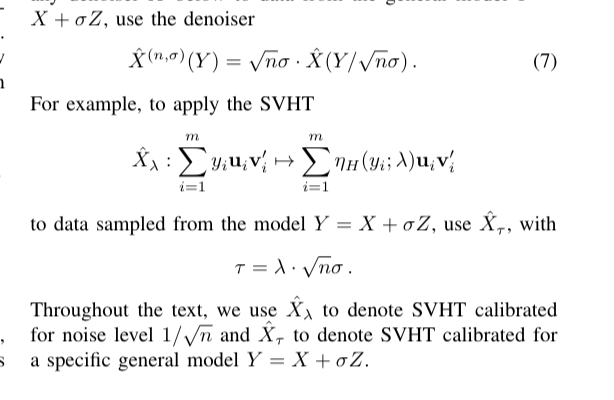
Singular-value hard-thresholding derivation
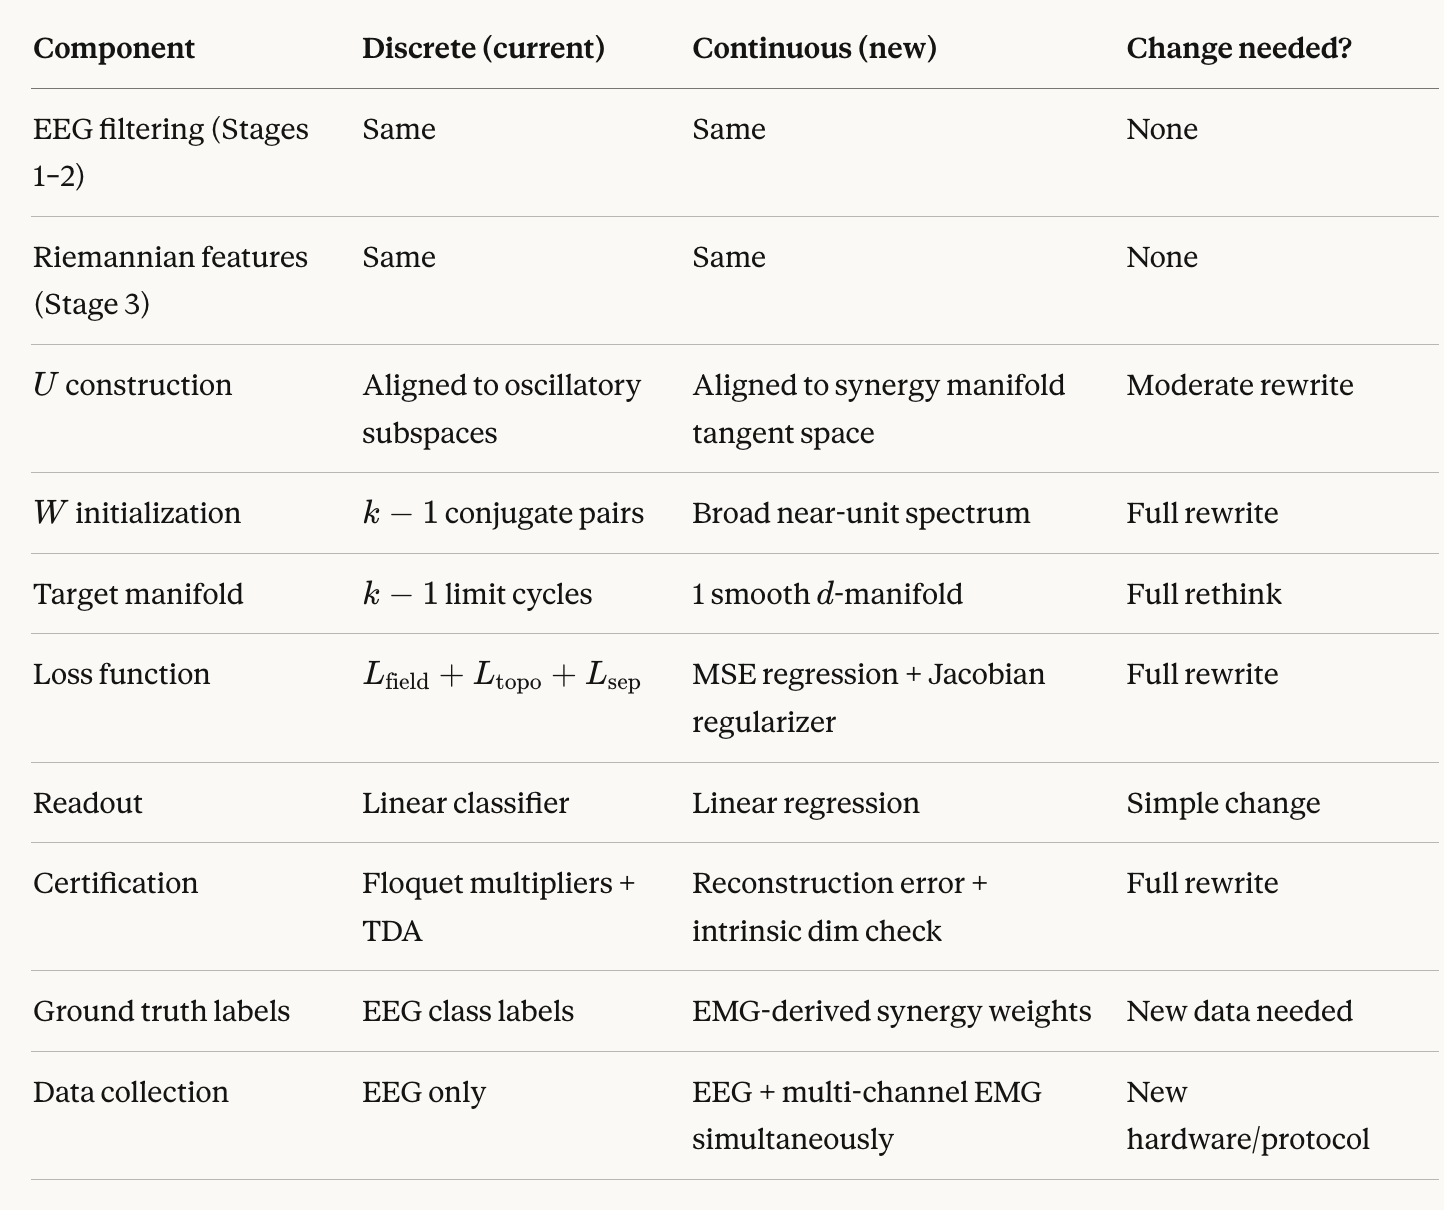
Discrete and continuous control design options
version caveat: several of these drafts are superseded or removed in March. The creation of a .tex file is not proof that its claims survived later review.
archived code references: 82921aa, c4d44f0.
- review questions: what estimation target and noise assumptions enter each bound? Are those assumptions shared across drafts? What interface converts the output into actuator commands, and how are uncertainty/limits handled? Preserve these as proof/design obligations until the relevant document and experiment resolve them.