
THALis: streaming and hand-simulation separation
hand sim first with predictable inputs, no EEG involved. if a joint does something weird i need to know which side broke; small command replay tool might be useful later
archived reorganization: b249471 moves acquisition into src/unicornlsl/stream.py, introduces src/handsim/sim.py, and adds Shadow Hand E MuJoCo assets under data/mujoco_models/. The assets include collision/visual meshes, URDF descriptions and XML environment files.
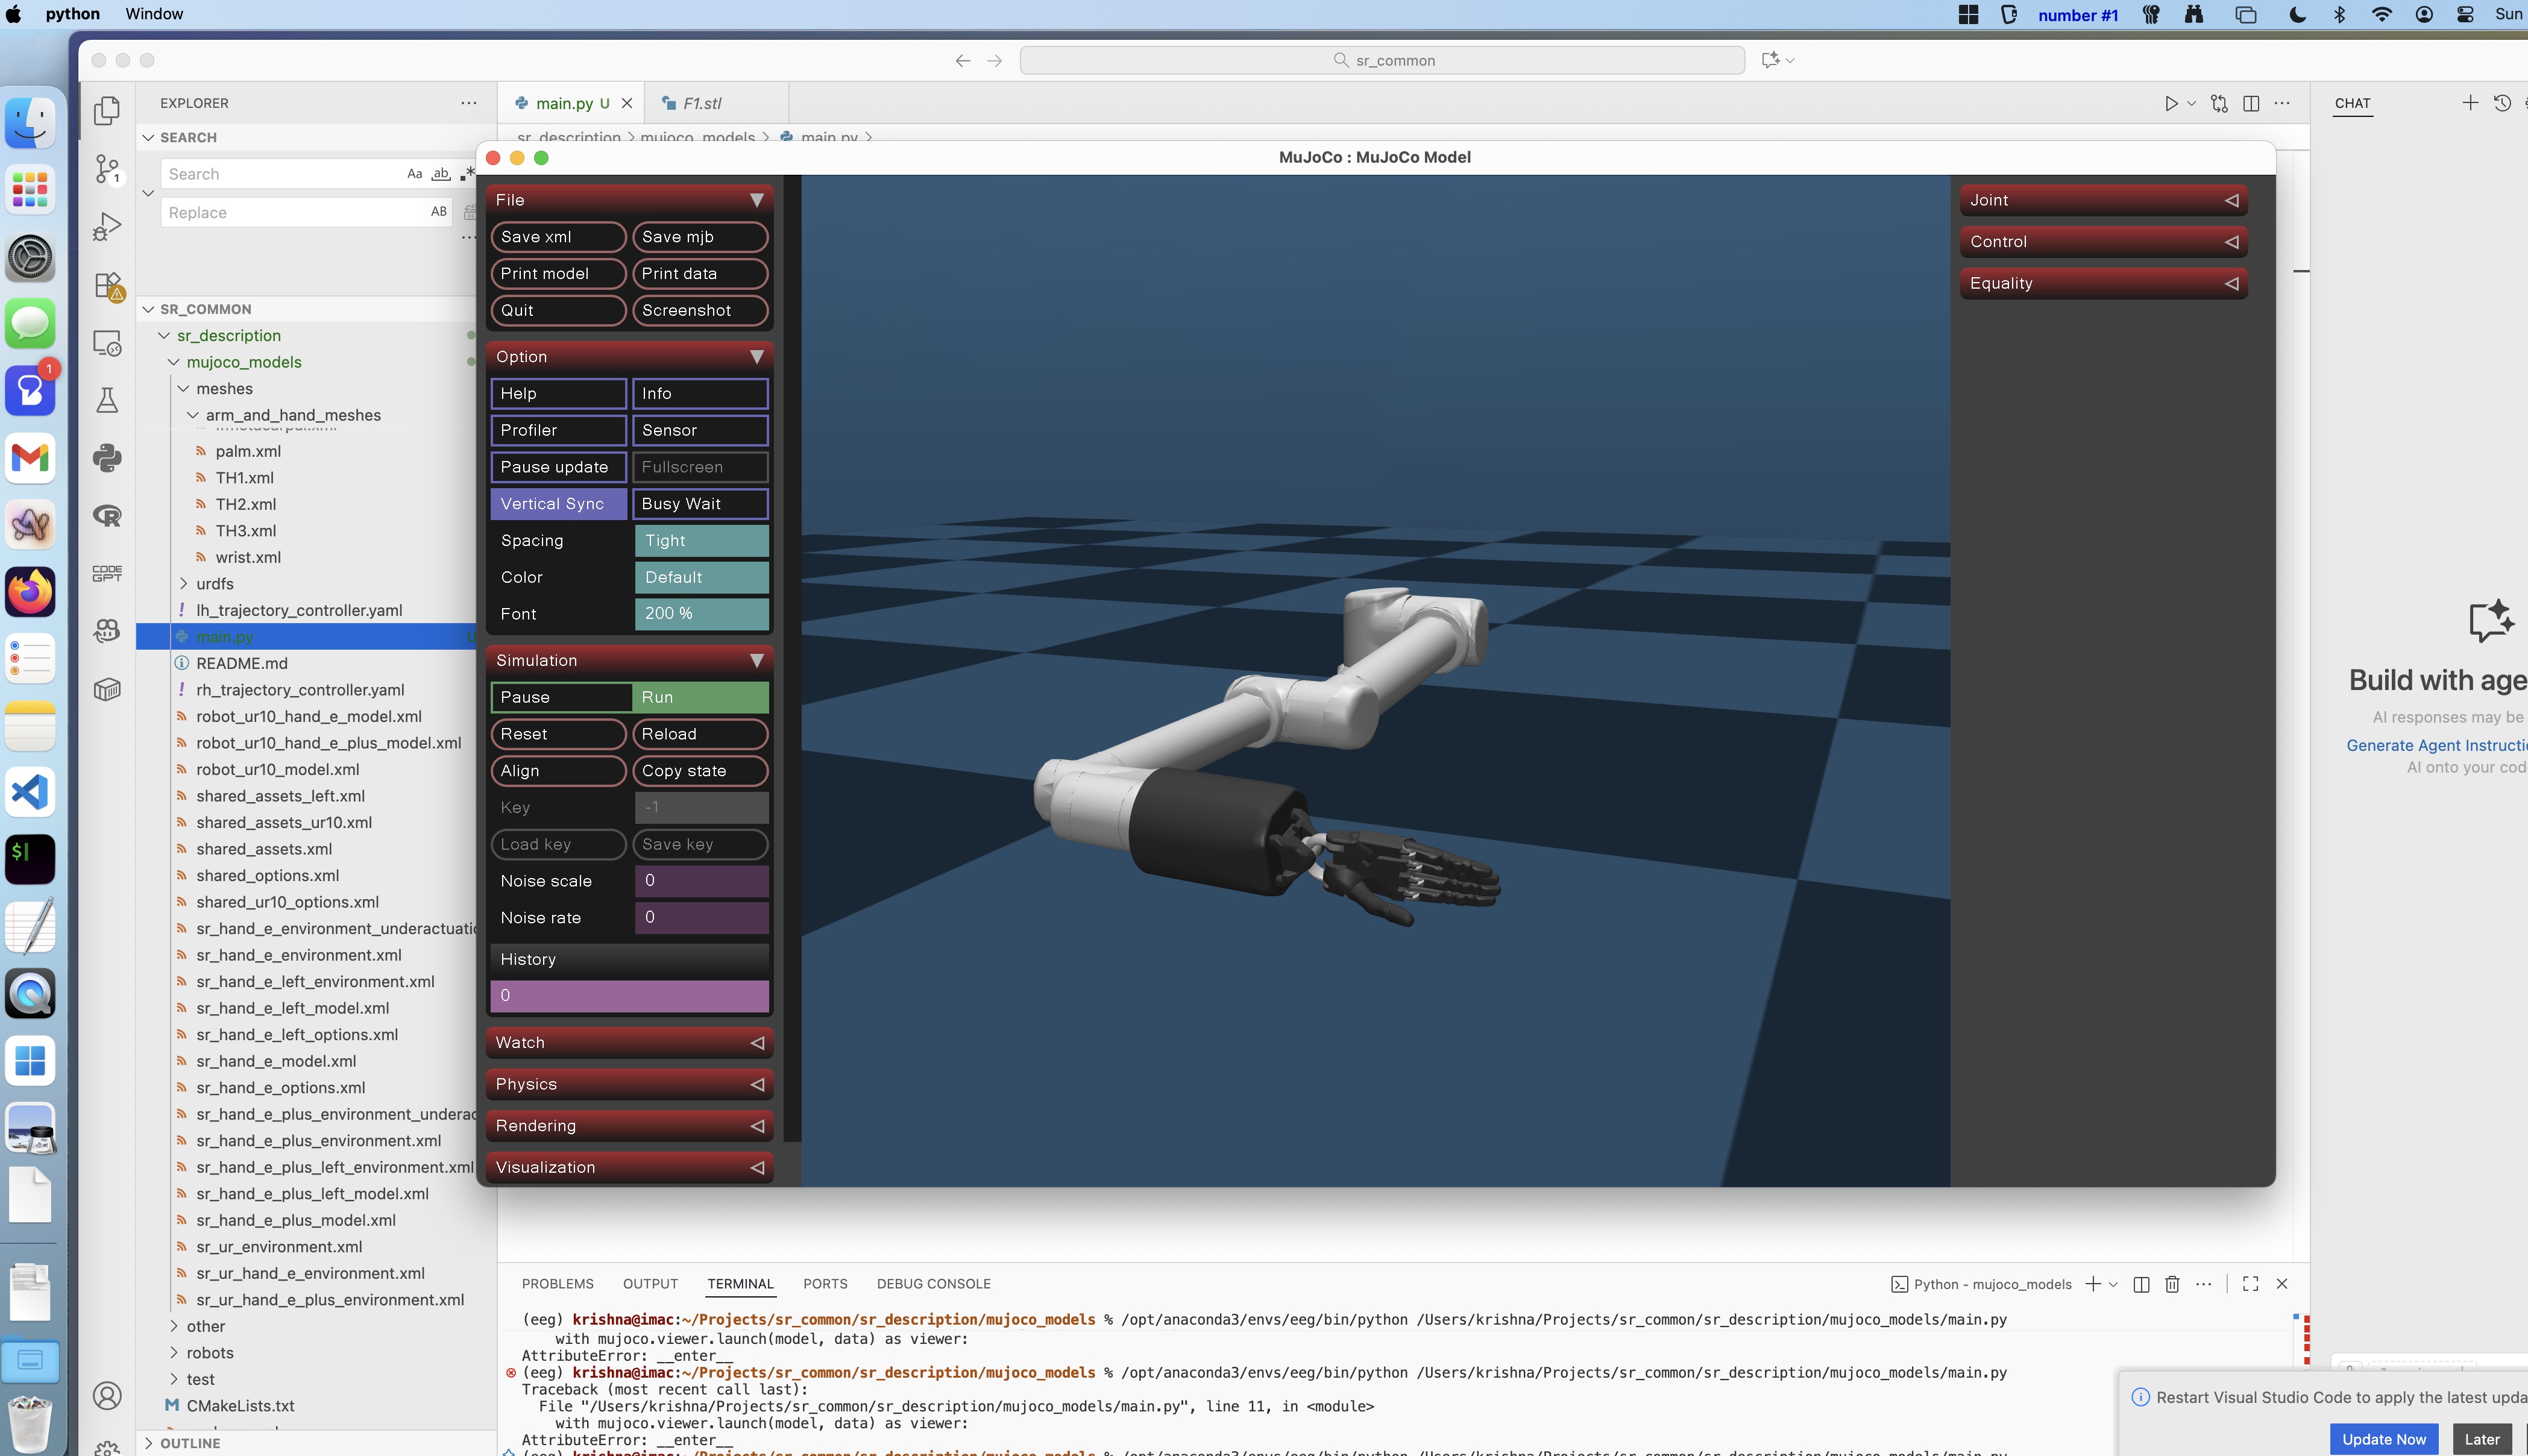
MuJoCo hand model and launch code
Shadow Robot Gazebo installation guide
interface question: the acquisition layer produces timed EEG samples; the hand simulator consumes control values/poses. Keep those interfaces independent so the simulator can be tested with deterministic inputs before coupling it to a decoder.
- path history:
data/mujoco_models/later becomesdata/mujoco/, and simulation code is relocated again. Use a commit-specific path when returning to this version; a path in the final archive may not exist in the initial tree.
- review questions: what joints/actuators are commanded, what units/ranges are expected, and how are limits handled? The presence of a dexterous hand model is not evidence that all its degrees of freedom were decoded from EEG.
- archived code references:
b249471.